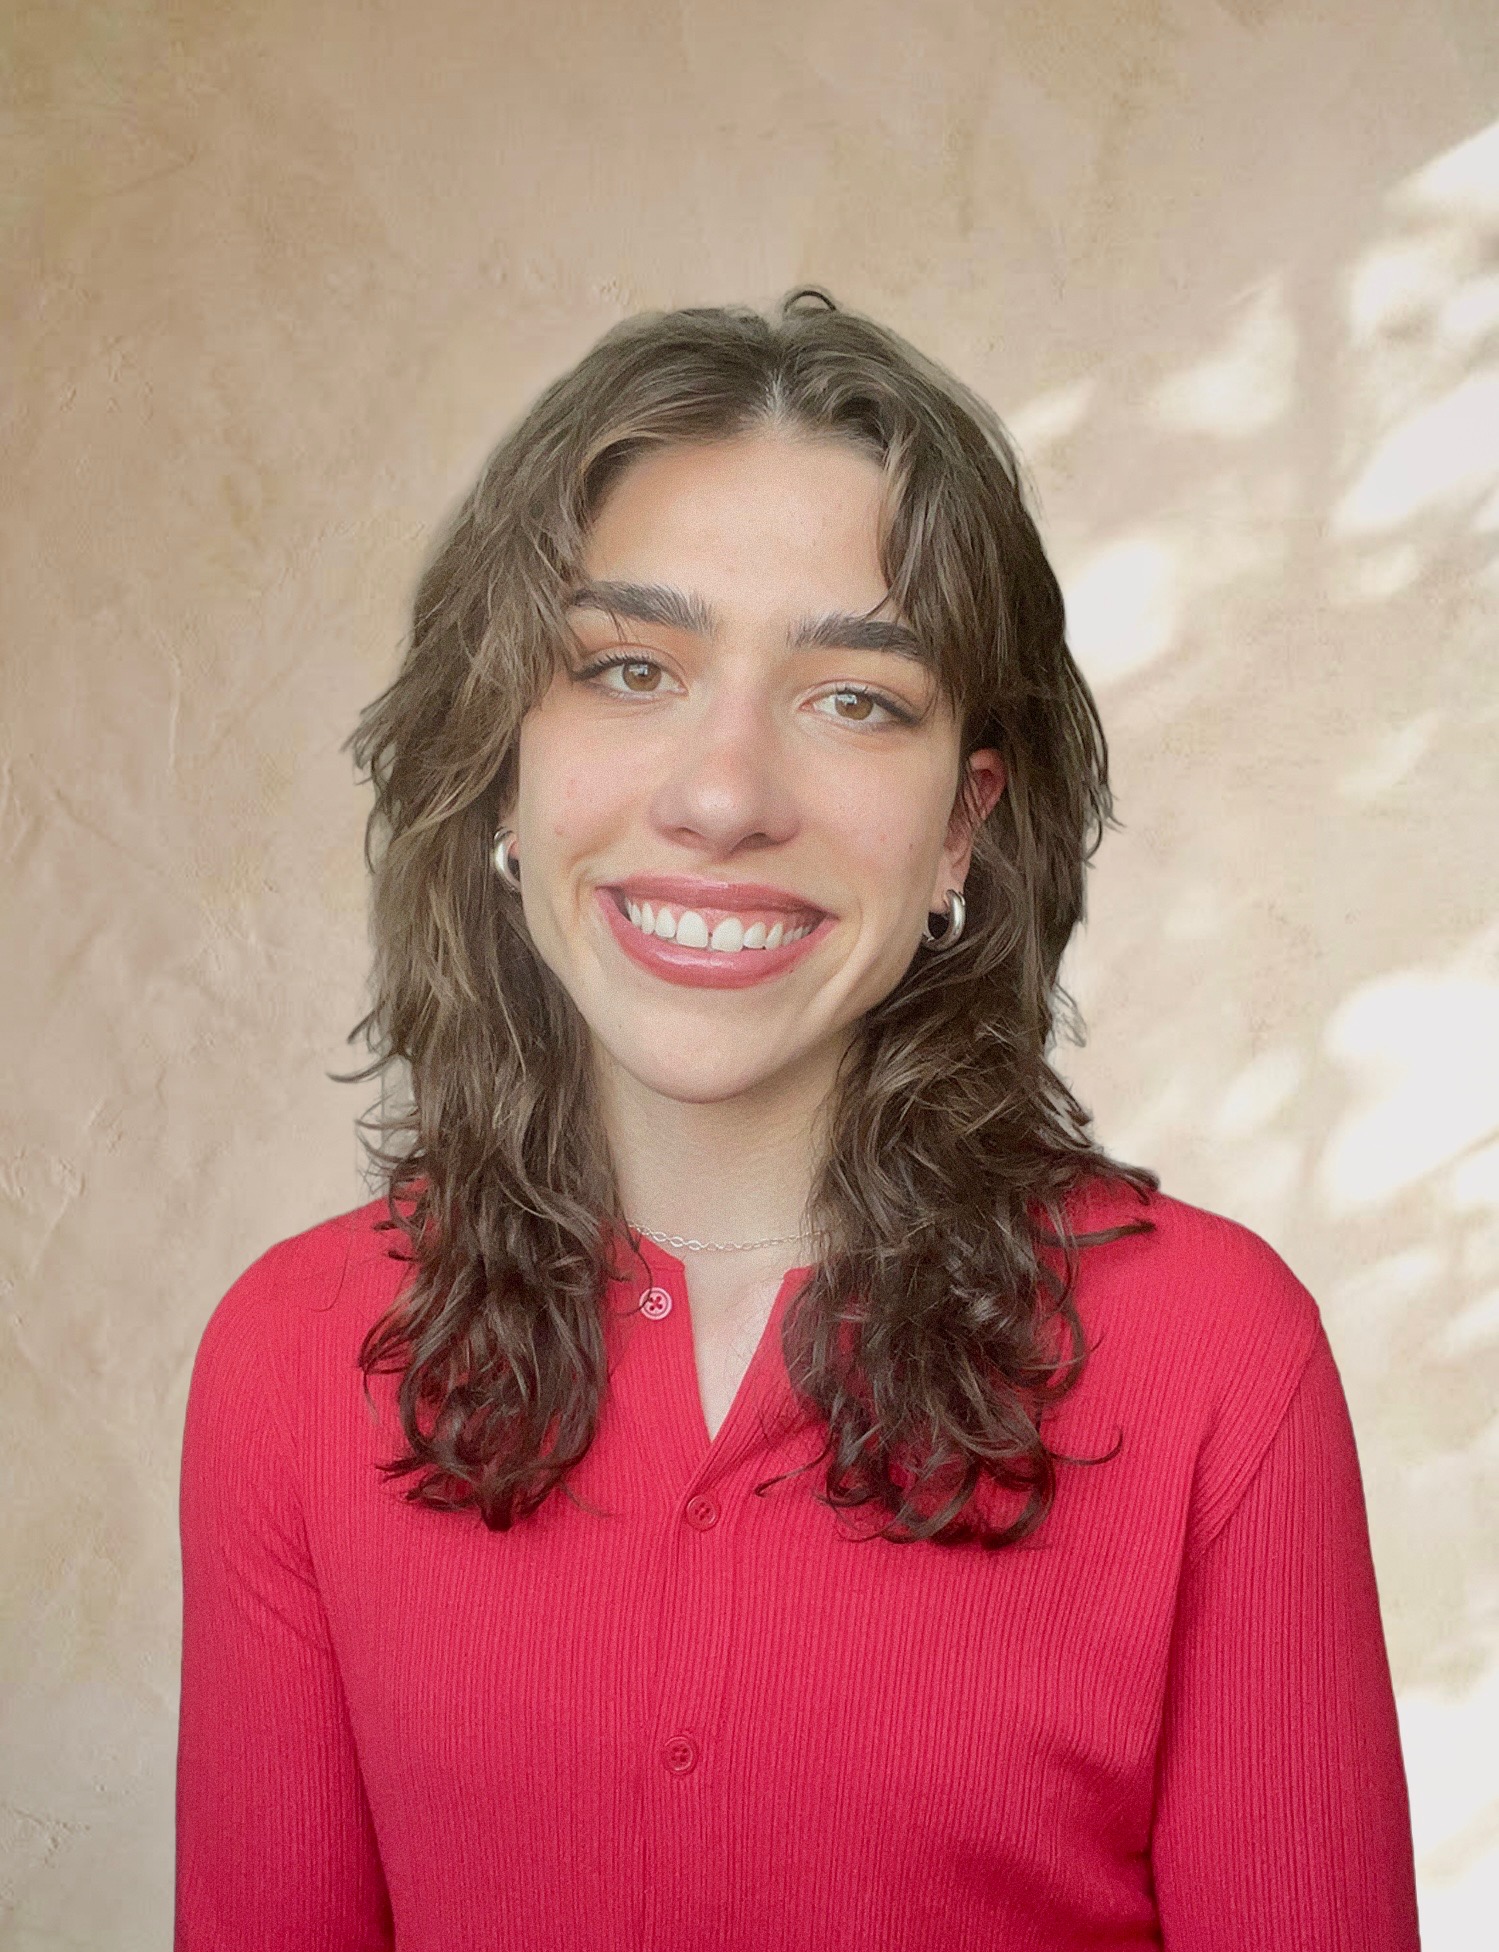
Julia researches Multi-Robot Task Assignment under communication constraints, developing online algorithm based on distributed optimization.
Julia researches Multi-Robot Task Assignment under communication constraints, developing online algorithm based on distributed optimization.